RoboCup 2026 Incheon (Korea)
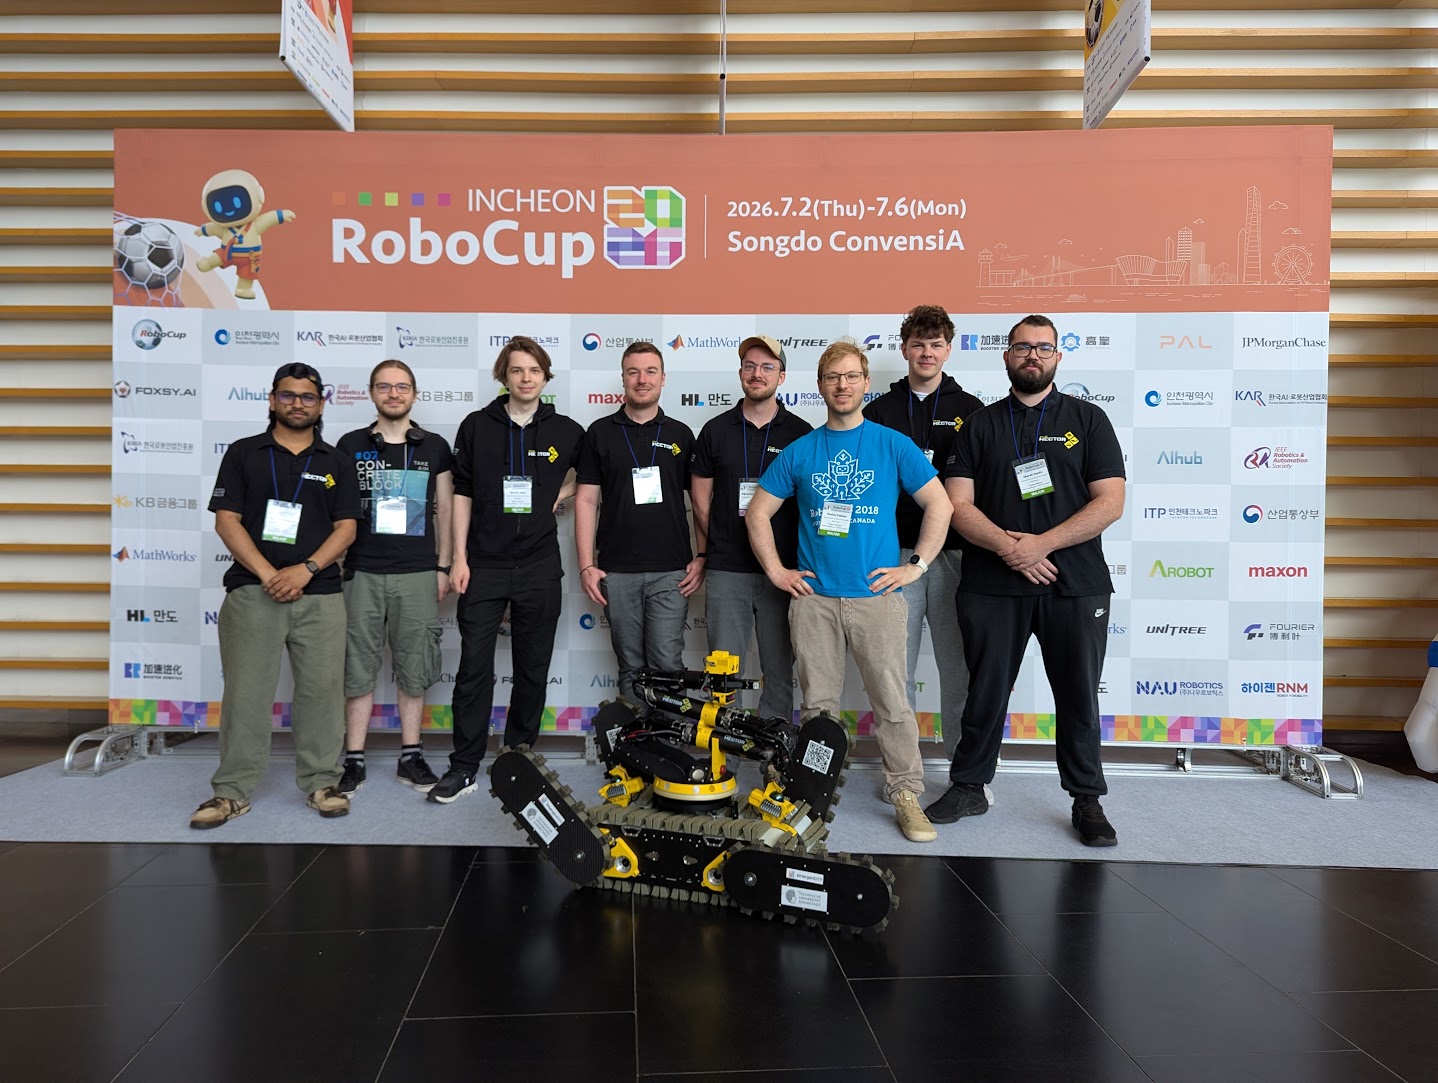
At the RoboCup Rescue World Championship 2026 in Incheon, Korea, Team Hector advanced to the semi-finals among a record number of 23 competing international teams.
We achieved a significant improvement in mobility after optimizing the belt profiles and adding an anti-friction base plate. In particular, Athena’s turning performance improved due to a more efficient distribution of ground contact. Extensive work on hardware robustness and low-level software reliability also paid off, as Athena experienced zero hardware faults across all RoboCup runs.
We also further extended our mapping capabilities by incorporating thermal information into our colored point cloud during the maze run, being the only team to do so. This constitutes a significant additional source of information that can aid in victim search and localization of safety hazards during rescue operations.
Additionally, we achieved robust pose estimation for dexterity objects for the first time, which we hope to expand into fully autonomous dexterity runs next year.
We are looking forward to the next championship in 2027, which takes place on our home turf, Germany.
PhD Students: Aljoscha Schmidt, Frederik Bark, Stefan Fabian
Master Students: Marek Daniv, Martin Volz, Dishant Dishant, Jonas Süß
Bachelor Students: Vladislav Praznik

